
[Soft Robotics, Teleoperation and Motion Control]

Dielectric Elastomer Actuators
An Attempt at the Performance and Design of a Modular Mobile Crawler Driven by a DEA Tube

Thermal Deformation Silicone Design
Performance Measurement of Heat-Deformable Silicone and Optimization of the Manufacturing Process for Pneumatic Robotic Arms
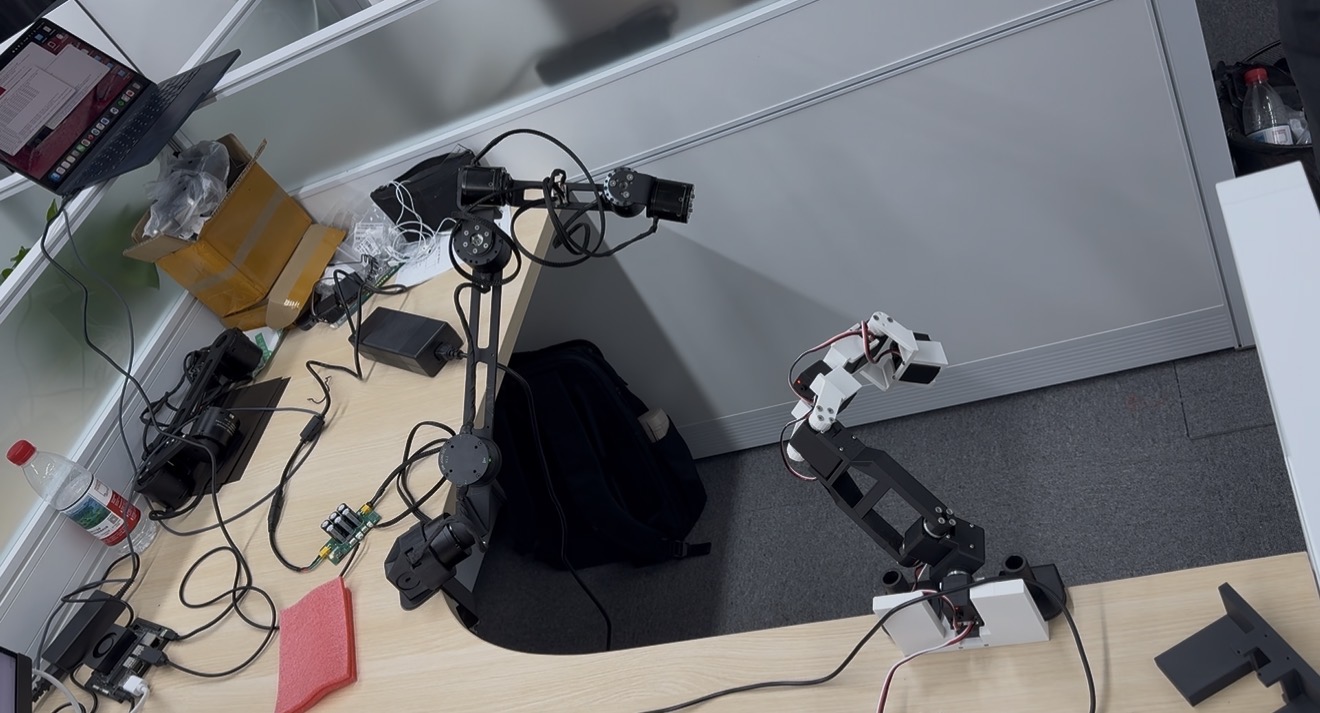
Windshape Internship
An exploratory internship at Windshape: a portable master arm with gravity compensation for teleoperation, and end-effector stabilization under base disturbances.